
MANAS voice interaction
Real-time speaking, listening and question-answering have been demonstrated on the MANAS humanoid platform. Motion, perception and interaction capabilities remain under active integration.

Built in Pune · Designed for the physical world
M CAD Solutions builds indigenous robotic platforms that connect mechanical engineering, embedded control, ROS 2, computer vision and digital twins—from prototype to real-world deployment.
What we build
We design the mechanical structure, integrate actuators and electronics, build the ROS 2 control layer, add computer vision and validate the complete system on real hardware.
Current development status
We publish progress as capabilities are integrated and demonstrated on physical hardware. These are current engineering milestones—not promises of a finished commercial product.
Real-time speaking, listening and question-answering have been demonstrated on the MANAS humanoid platform. Motion, perception and interaction capabilities remain under active integration.
Manual lead-through teaching, joint-state recording and autonomous path playback have been demonstrated through a ROS 2-connected control workflow.
Computer vision, calibration and robot-frame motion are being developed as an integrated pipeline for repeatable physical pick-and-place tasks.
Capability availability depends on the selected platform, configuration and deployment scope. Contact us for a current technical demonstration.
Product platforms
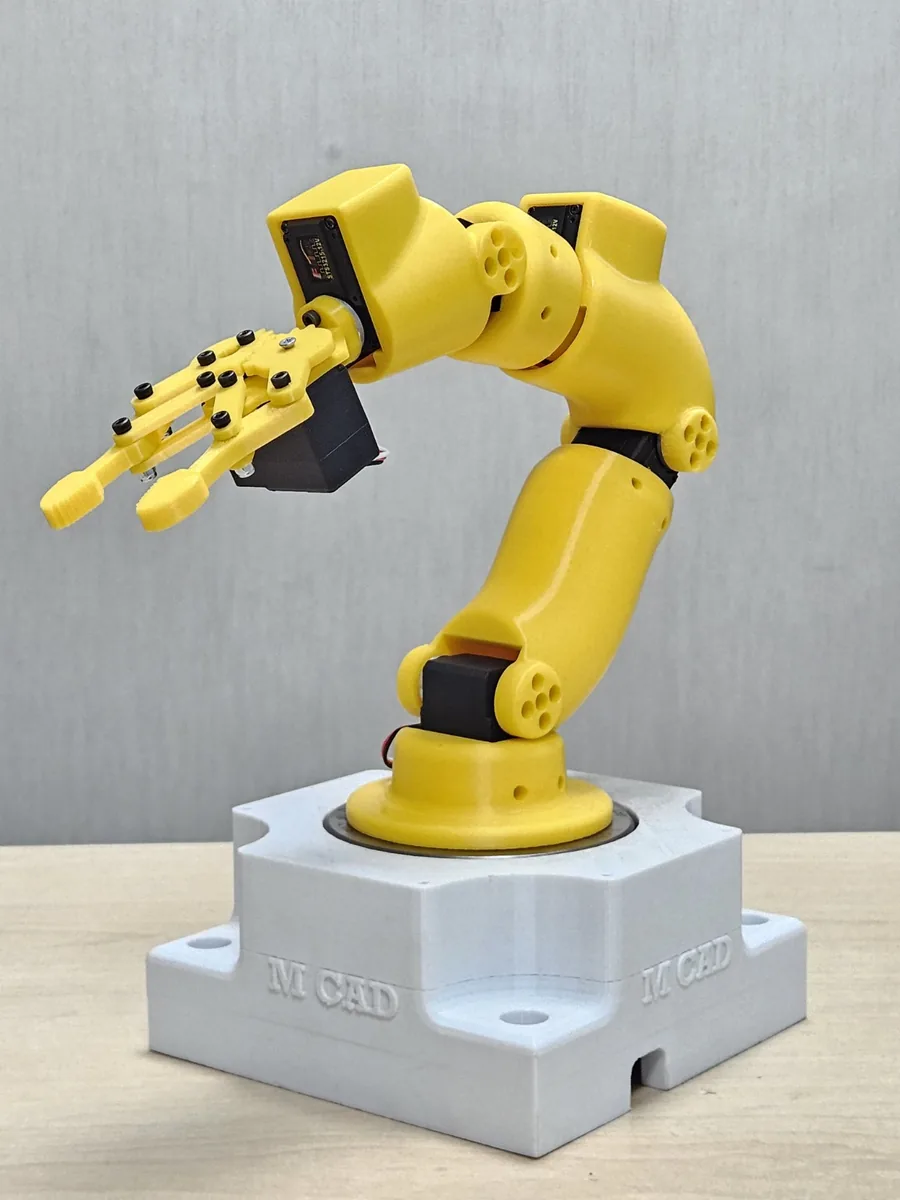
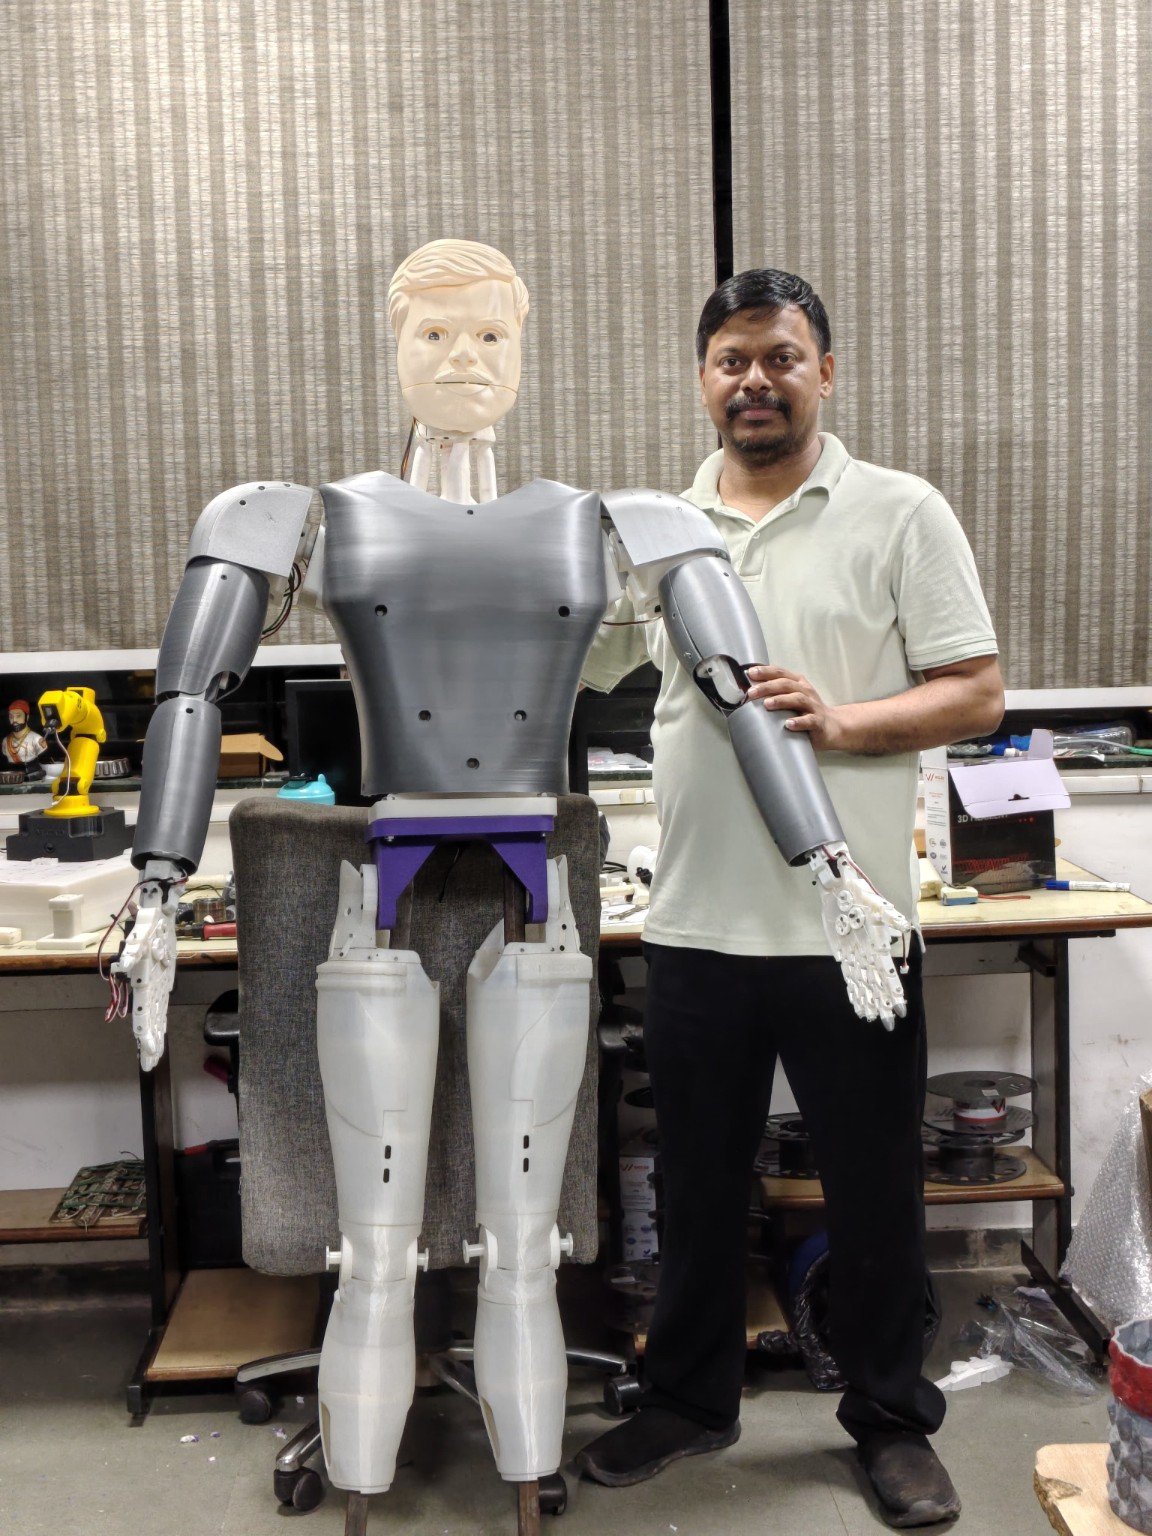
Two in-house robotics platforms—MANAS and Dexter—give us a hardware foundation for perception, manipulation, human interaction and simulation-to-real development.
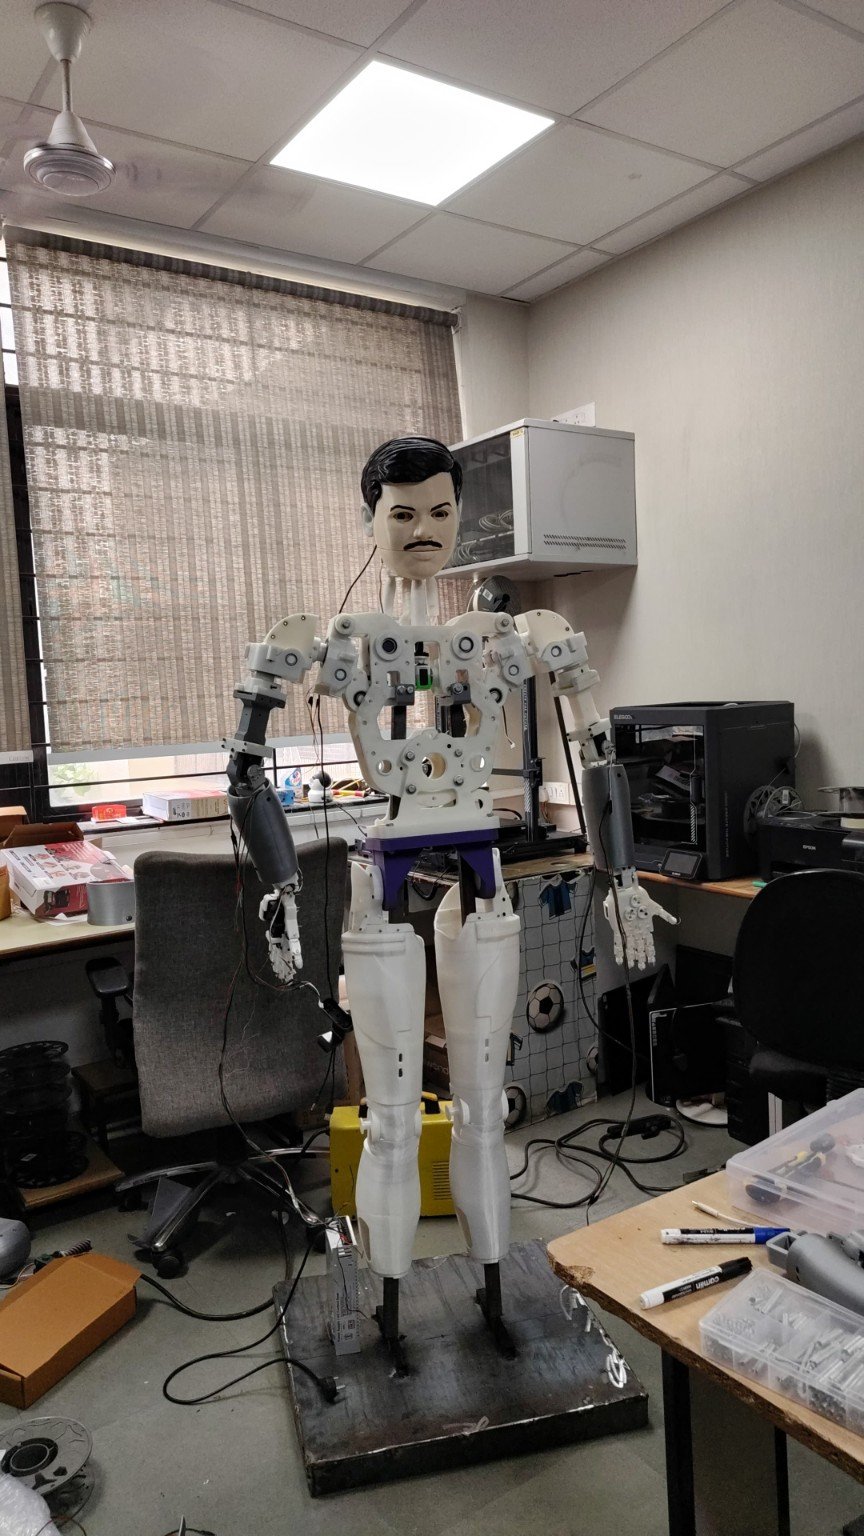
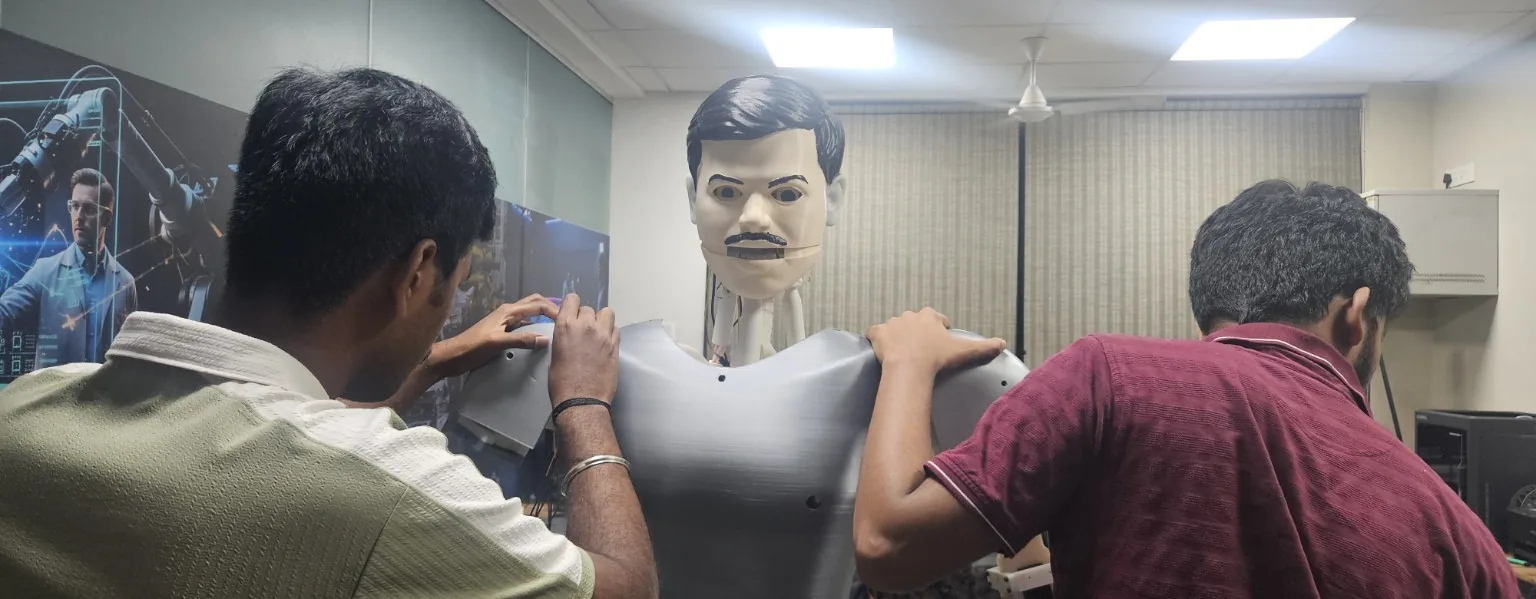
Humanoid / Physical AI
An embodied Physical AI research platform for articulated motion, gestures, voice, vision and human–robot interaction. Its purpose is to connect interaction research with a physical humanoid and a corresponding digital workflow.
A working physical prototype in active integration and testing.
6-DOF Manipulator
A compact manipulation platform for teaching motion, calibrating robot–camera workflows, developing pick-and-place and testing ROS 2 control against physical hardware.
A physical robot with a digital workflow for perception, control and experimentation.
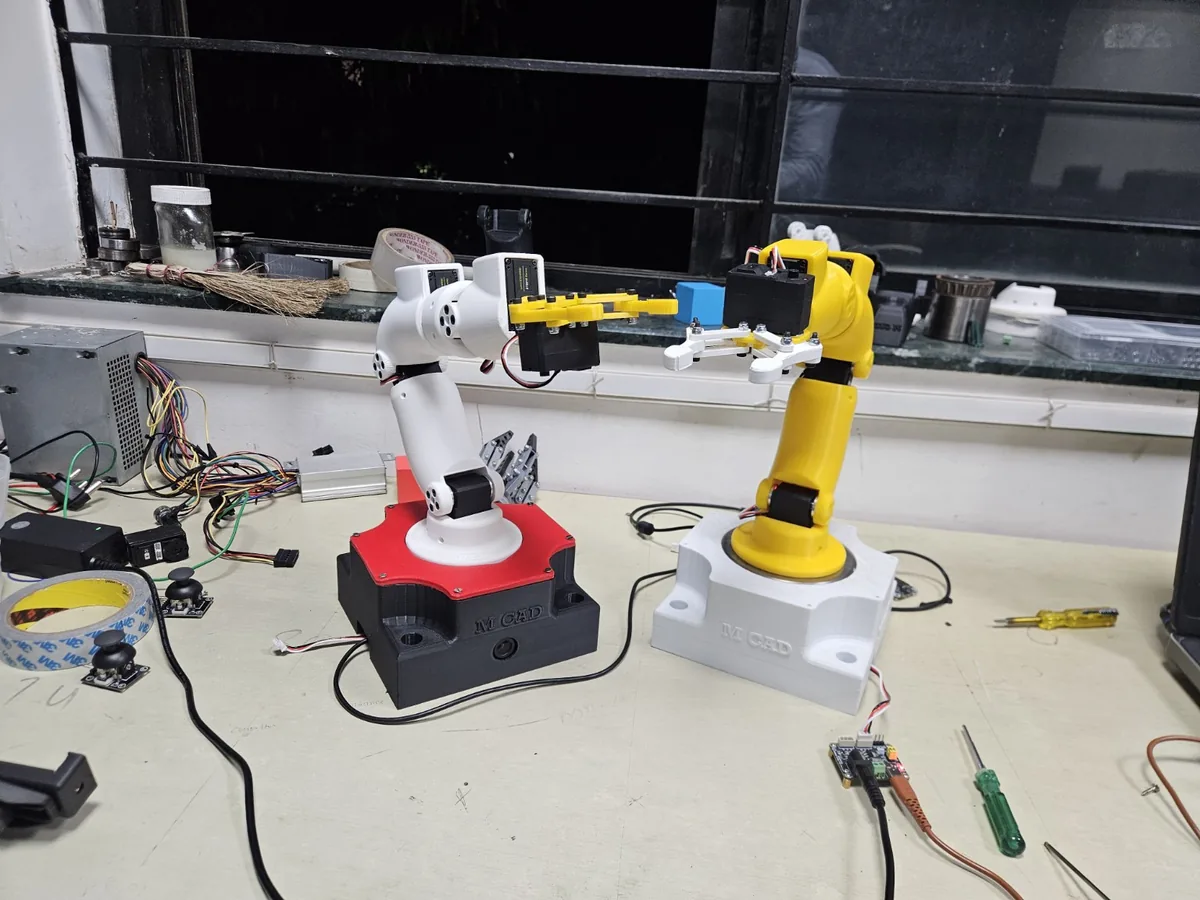
Project configuration
Selected appearance, identity and hardware options can be scoped for each deployment without turning the platform into a generic catalogue product.
Robot shell colour and finish can be selected to suit the lab, institution or demonstration environment, subject to manufacturing approval.
Approved institution or company name, logo treatment, asset identification and project labelling can be applied to the delivered system.
Tooling, cameras, sensors, compute and control accessories are selected around the intended research or pilot workflow.
Examples indicate available design directions, not stocked variants. Final configuration, lead time and validation depend on the agreed project scope.
Technology
Our robots are developed in-house across mechanical design, electronics, control, ROS 2, perception and digital-twin workflows.
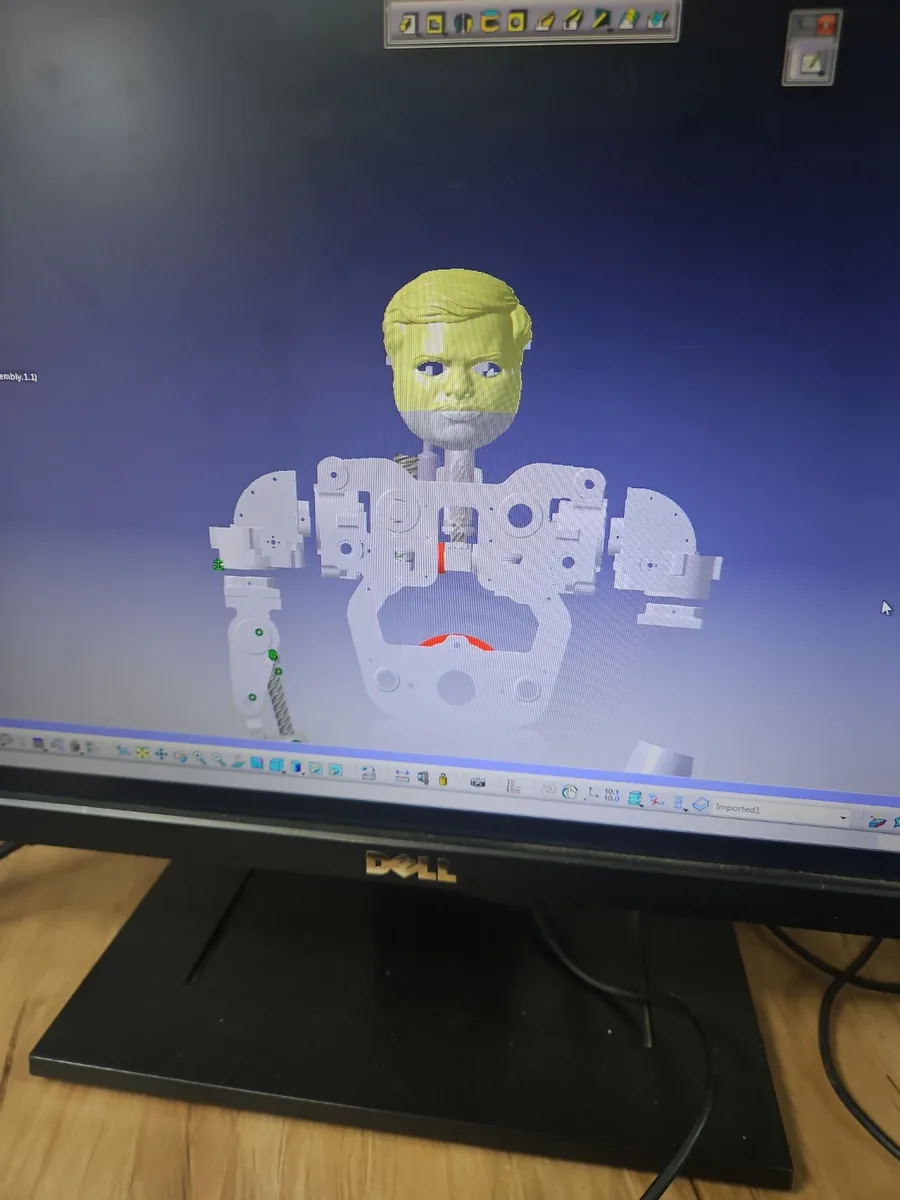
A robot only works when every layer is engineered to work together.
Mechanisms, structure, joint packaging, bearings, DFM and rapid physical iteration.
Actuators, sensors, embedded controllers, motor communication and joint calibration.
URDF, control interfaces, simulation, Unity and Gazebo workflows, and real-robot synchronization.
Object detection, calibrated perception and intelligent interaction developed toward reliable physical robot motion.
Physical robot ↔ digital clone
Each lab platform begins with a physical robot. A project-specific Unity digital clone represents selected geometry, joint structure, limits, tooling and interfaces so work can be rehearsed, inspected and compared before physical validation.
These are industrial-style simulation workflows, not a claim of feature parity with every industrial simulation package. Availability depends on platform and project phase.
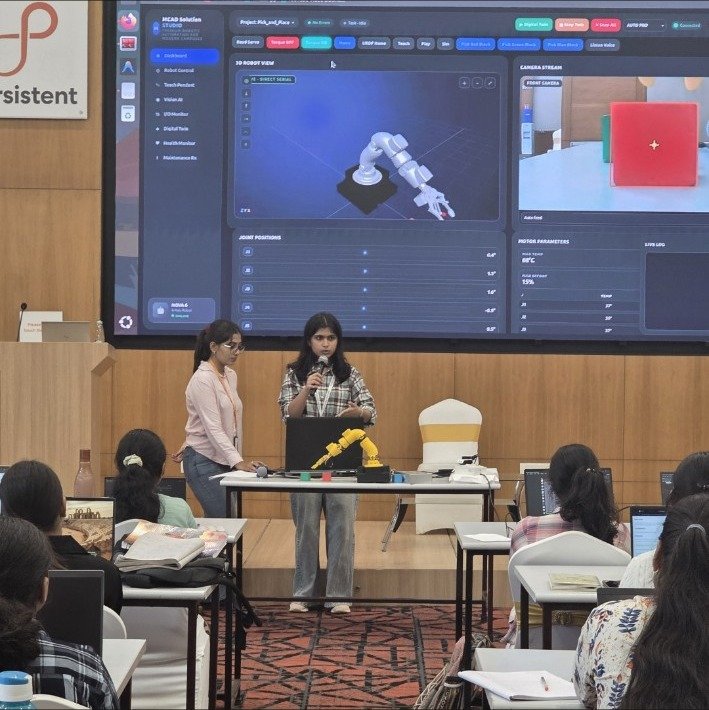
Deployments & engagement
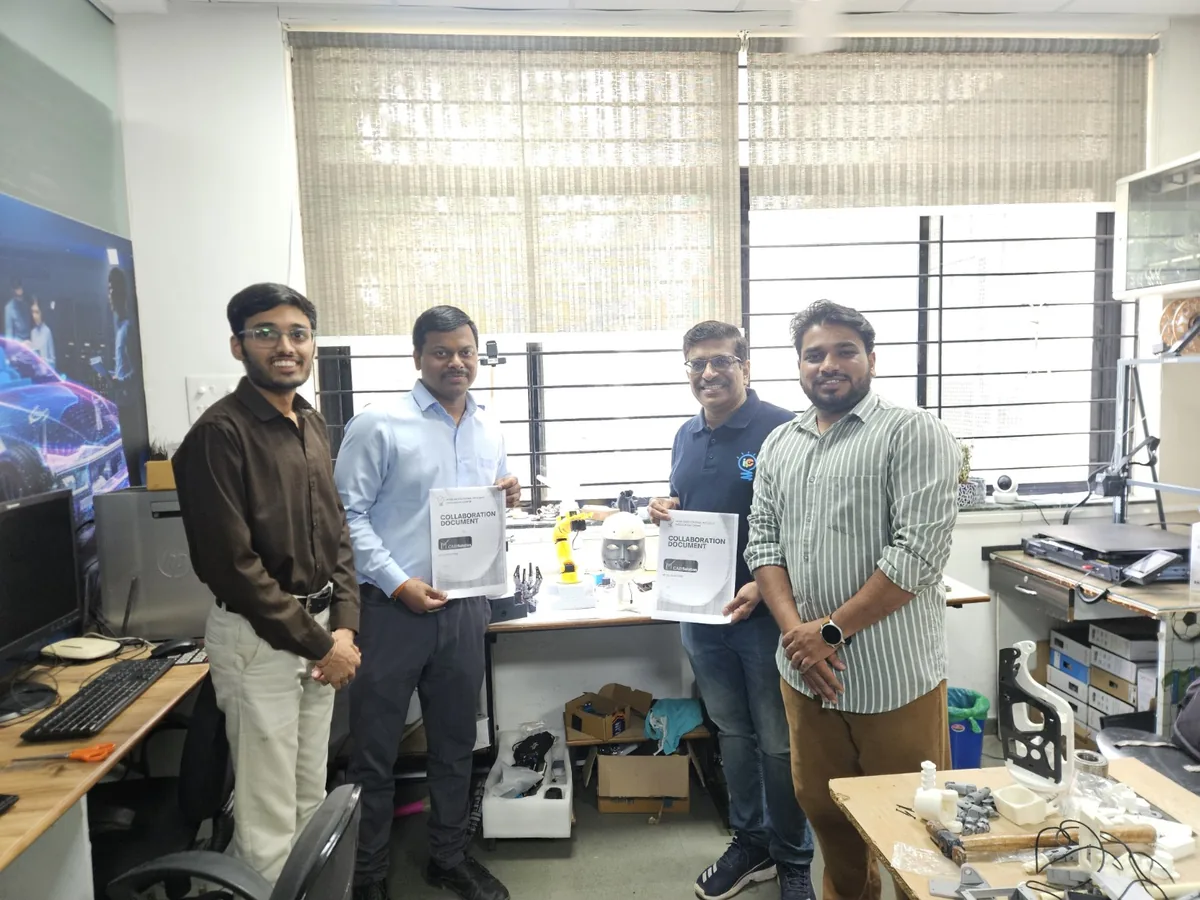
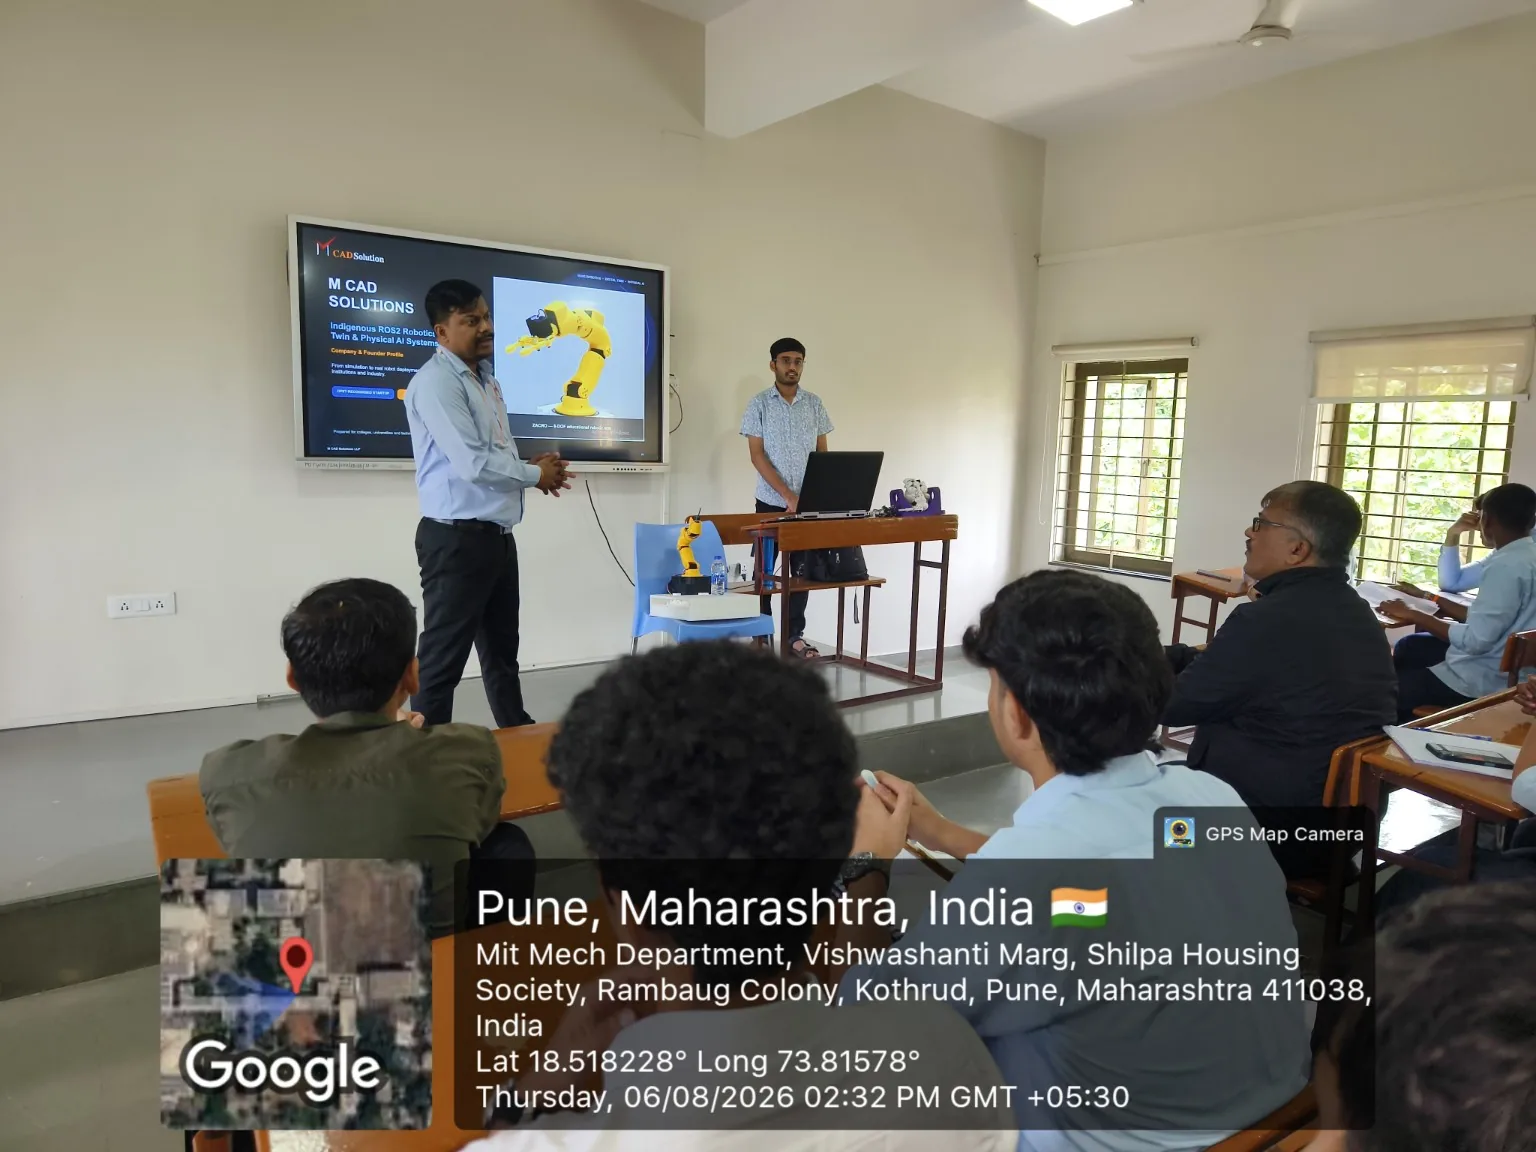
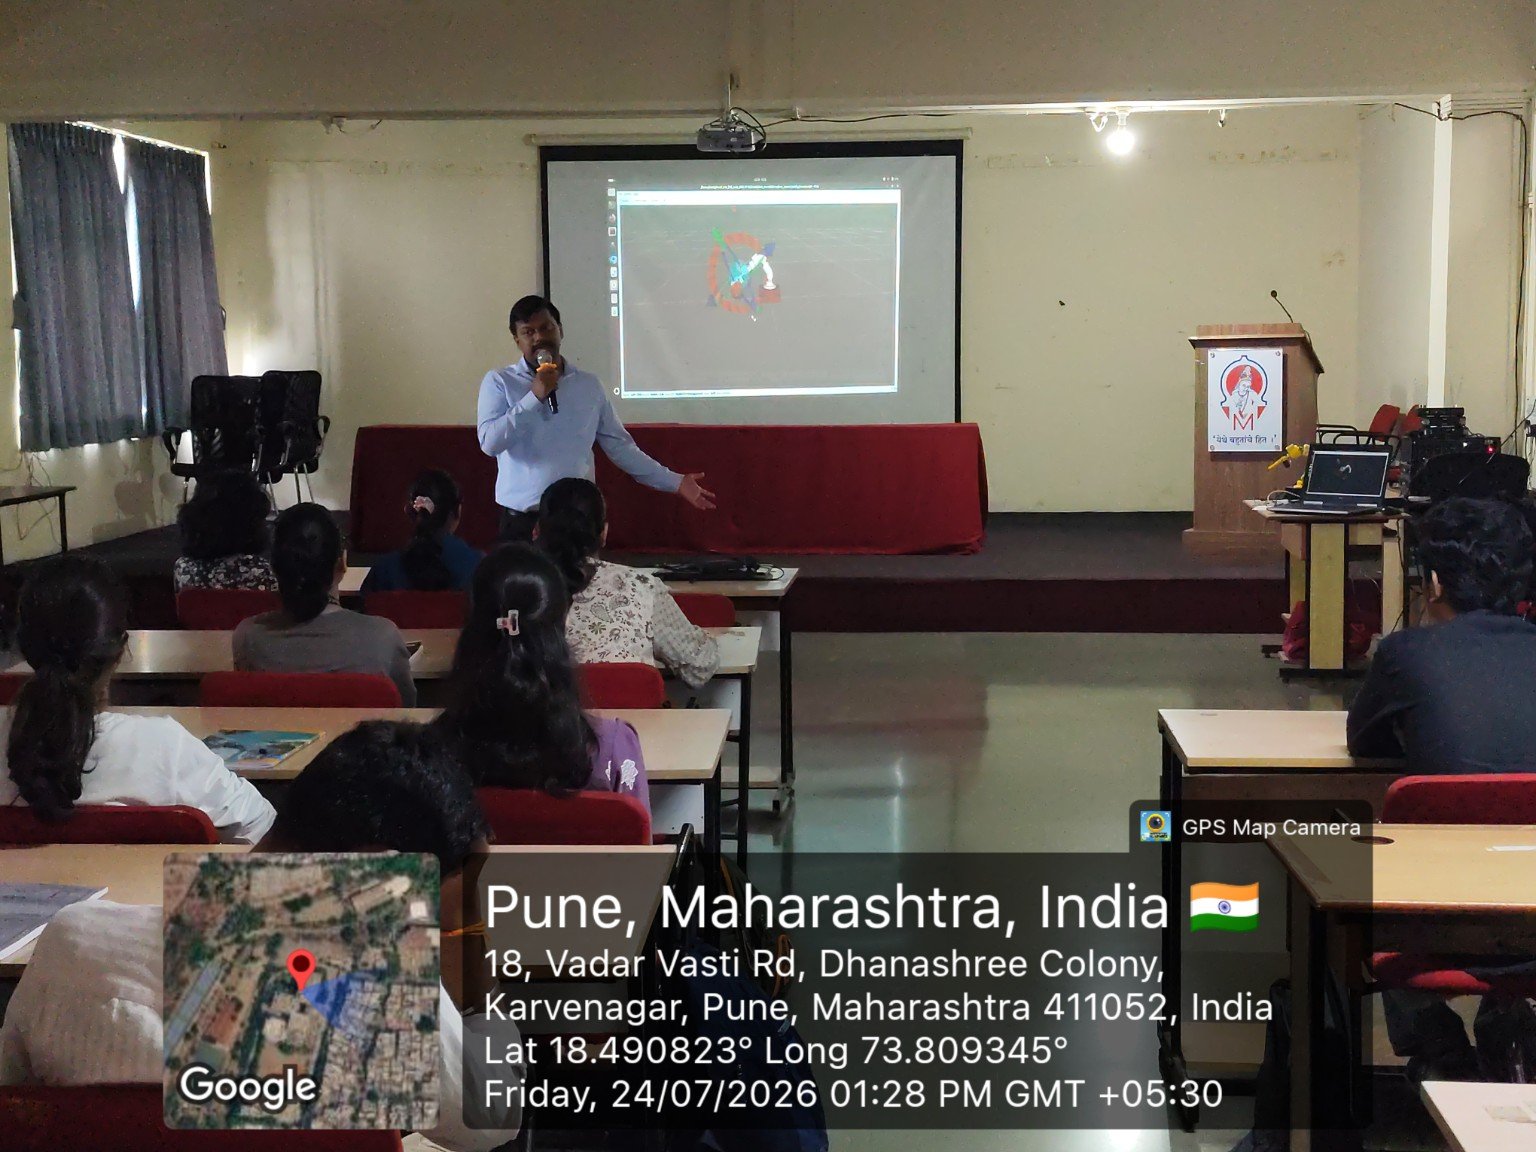
Hands-on robotics initiatives supporting demonstrations, applied research and engineering experimentation.
Mechanical design, simulation, control and real robot hardware developed as one connected workflow.
Support for institutions building practical robotics infrastructure around real hardware and digital workflows.
Institutional & research partnerships
We work with universities, research groups, innovation programs and industry partners on Physical AI platforms, pilot deployments and long-term robotics capability.
Create a shared engineering environment where teams can model, simulate, integrate, test and validate the same robot across digital and physical systems—from robot design and digital clone to task rehearsal and real-hardware demonstration.
Maintenance, updates and ongoing technical support are defined in the project proposal and support scope.
Use MANAS and Dexter as development platforms for perception, manipulation, human–robot interaction, ROS 2 and digital-twin research.
Plan the system architecture, integrate hardware and simulation, validate workflows and complete technical handover for a sustainable institutional facility.
Develop pilot projects, evaluate components and compute, and co-create Physical AI applications with measurable engineering milestones.
Accelerator & ecosystem readiness
We are advancing working robotic platforms into repeatable products and deployments, and are seeking relationships with accelerator programs, compute partners, research institutions and manufacturing networks.
Structured pilots with institutions and research teams to convert demonstrated capabilities into repeatable deployment packages.
GPU-accelerated vision, simulation, human–robot interaction and real-time robotics integration for physical systems.
Design-for-manufacture, component reliability, actuator packaging, quality processes and scalable assembly.
Collaboration around Physical AI, manipulation, digital twins, humanoid interaction and applied robotics pilots.
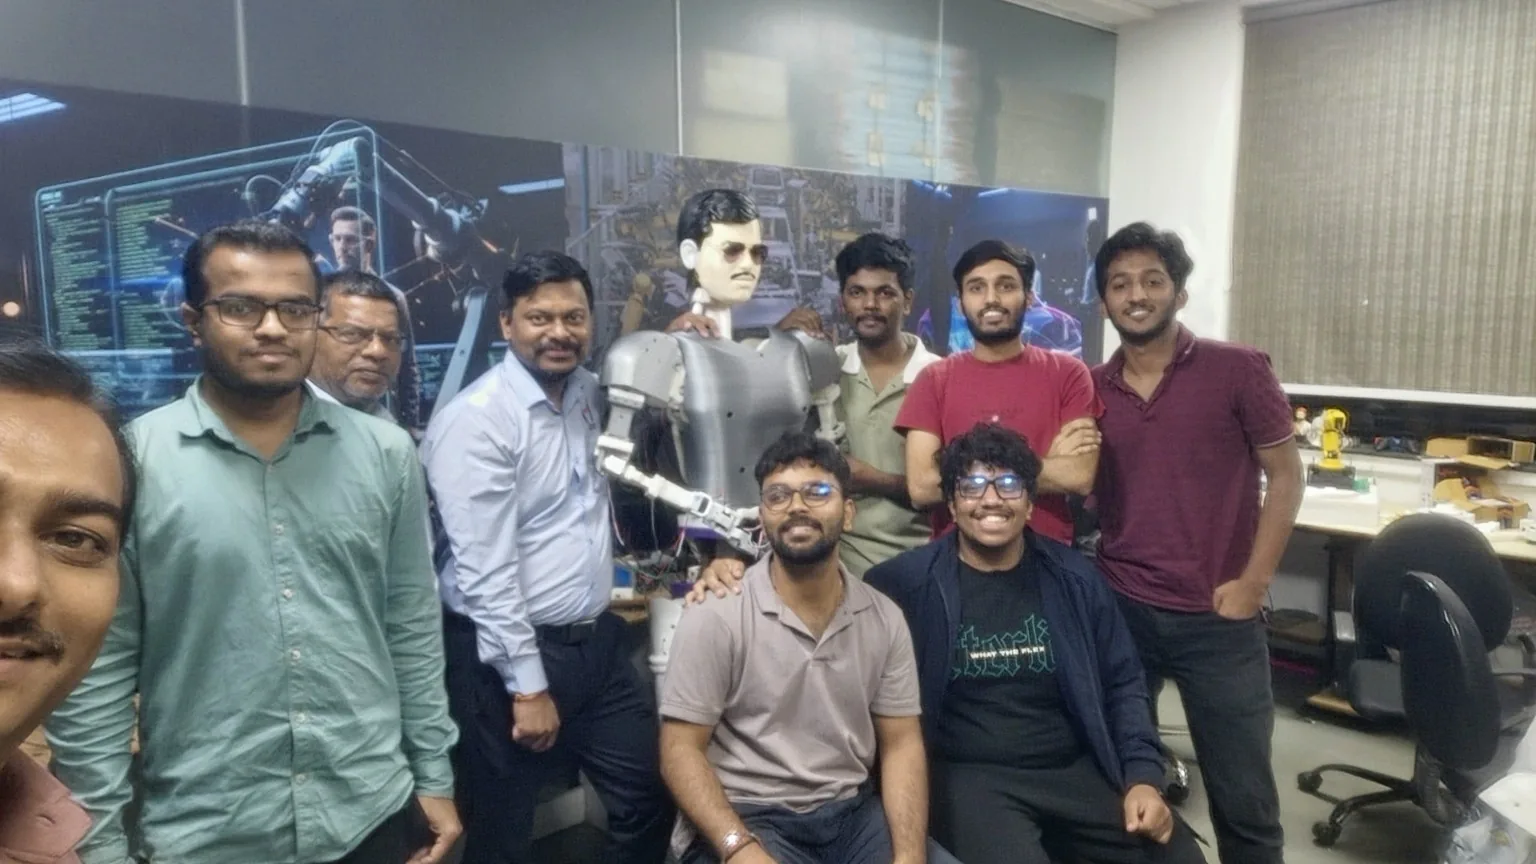
About M CAD Solutions
18 years of experience across robotics automation and mechanical design, leading product engineering and system integration.
Robotics software and development, contributing to the software layer that connects simulation, control and real hardware.
About us
We combine mechanical engineering, robotics software and digital twins to build machines that can sense, move, interact and perform useful physical tasks.
Design and develop robots, digital twins and automation systems for research, institutional deployment and real-world applications.
Create humanoids, manipulators and intelligent robotic systems that can perceive, interact and operate in the physical world.
Product demos · Research · Labs · Partnerships
Tell us what you are building or evaluating. We welcome product demonstrations, institutional deployments, applied research, pilot projects and ecosystem partnerships.
Share a few details and continue through email or WhatsApp.